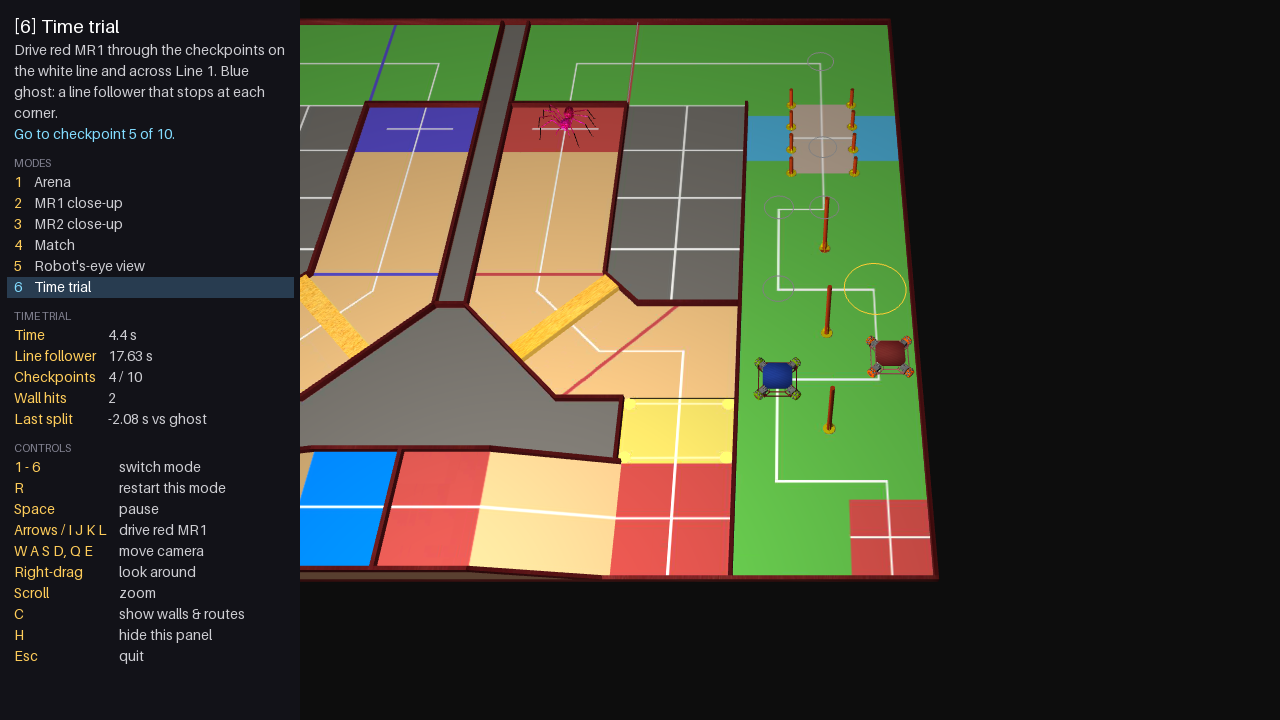
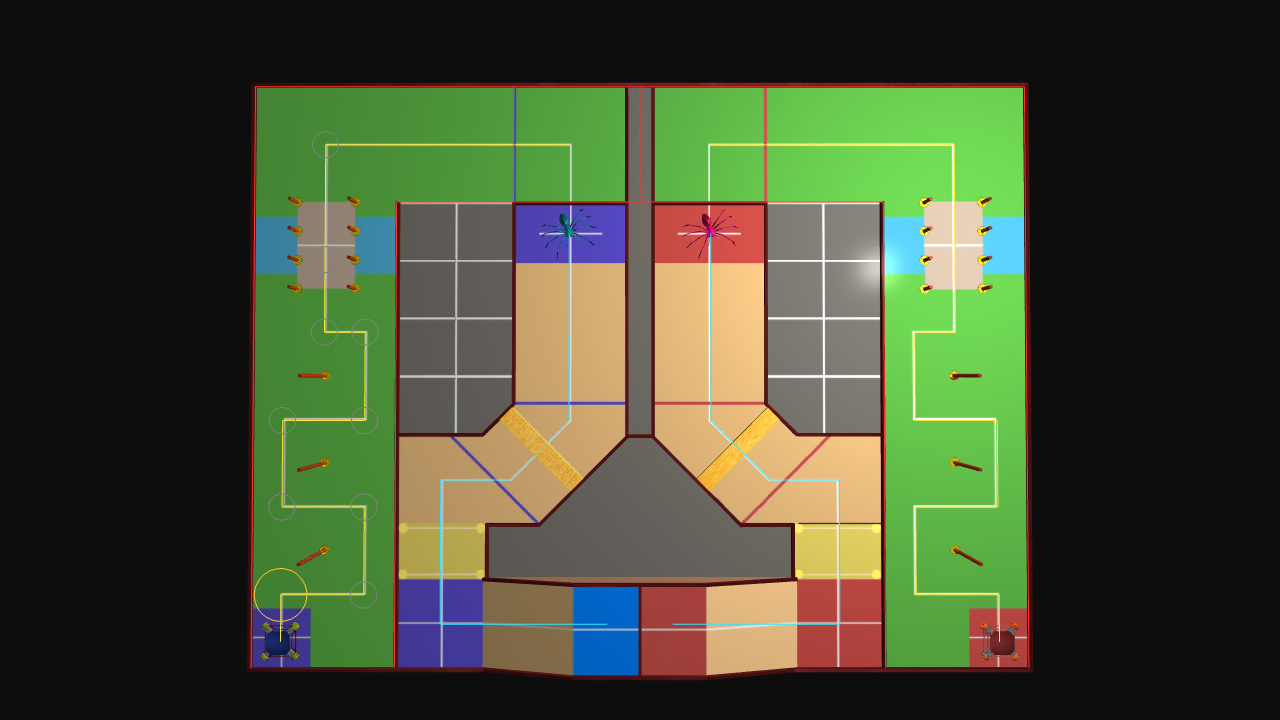
In ABU Robocon 2019, a wheeled robot (MR1) carries the Gerege through a forest of poles and hands it to a four-legged robot (MR2), which crosses a sand dune and a tussock and climbs a mountain. The first MR2 to reach the top wins.
// Overview
Written in Python with moderngl, GLFW and PyGLM, using Blender models of the arena and robots. Robot routes are the white guidelines measured from the floor texture, and MR2's height follows the sand dune and mountain. The simulation is independent of frame rate and covered by 124 unit tests.
// Gallery
// Features
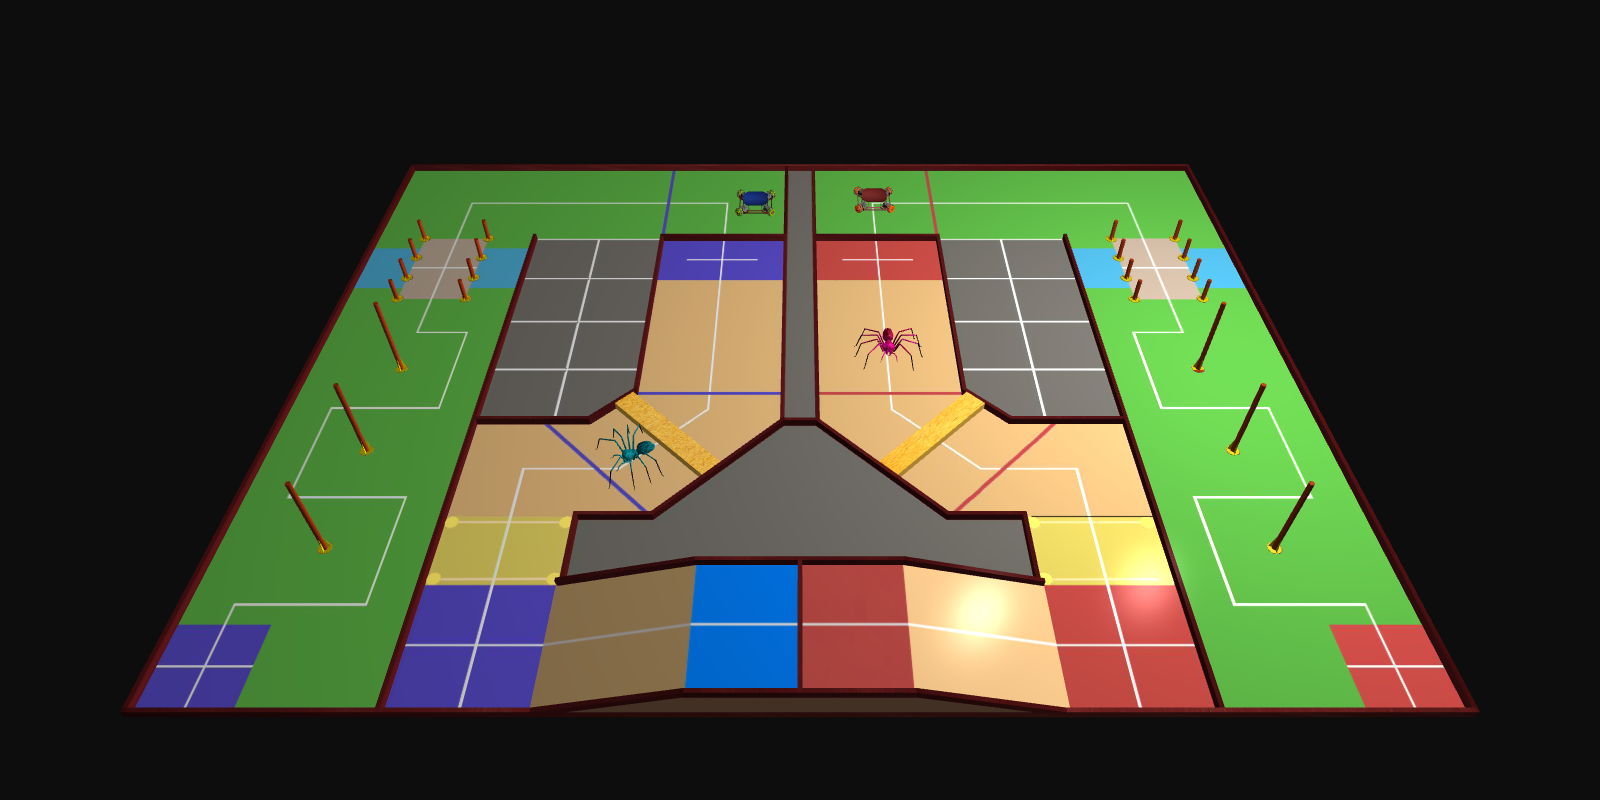
The full field and both teams' robots, loaded from OBJ/MTL and shaded with Blinn-Phong lighting.
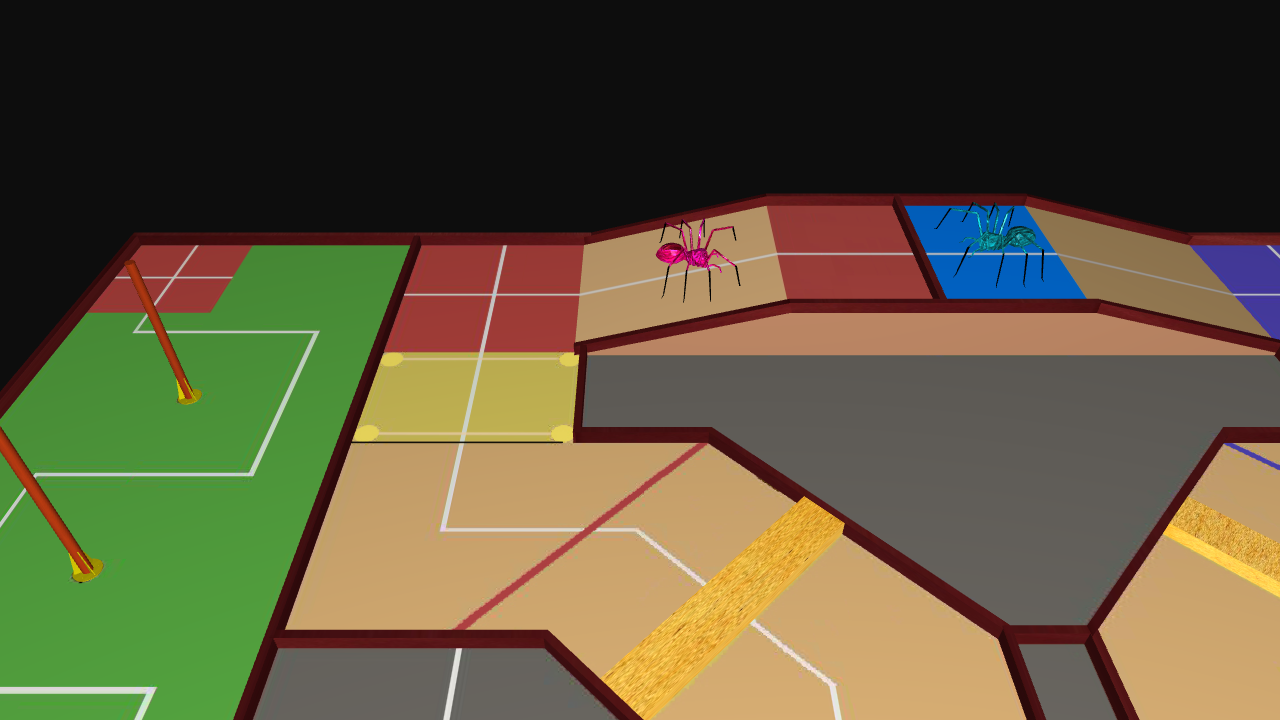
MR1 follows the white guideline through the forest like a line follower, and MR2 crosses the sand dune and tussock and climbs the mountain.
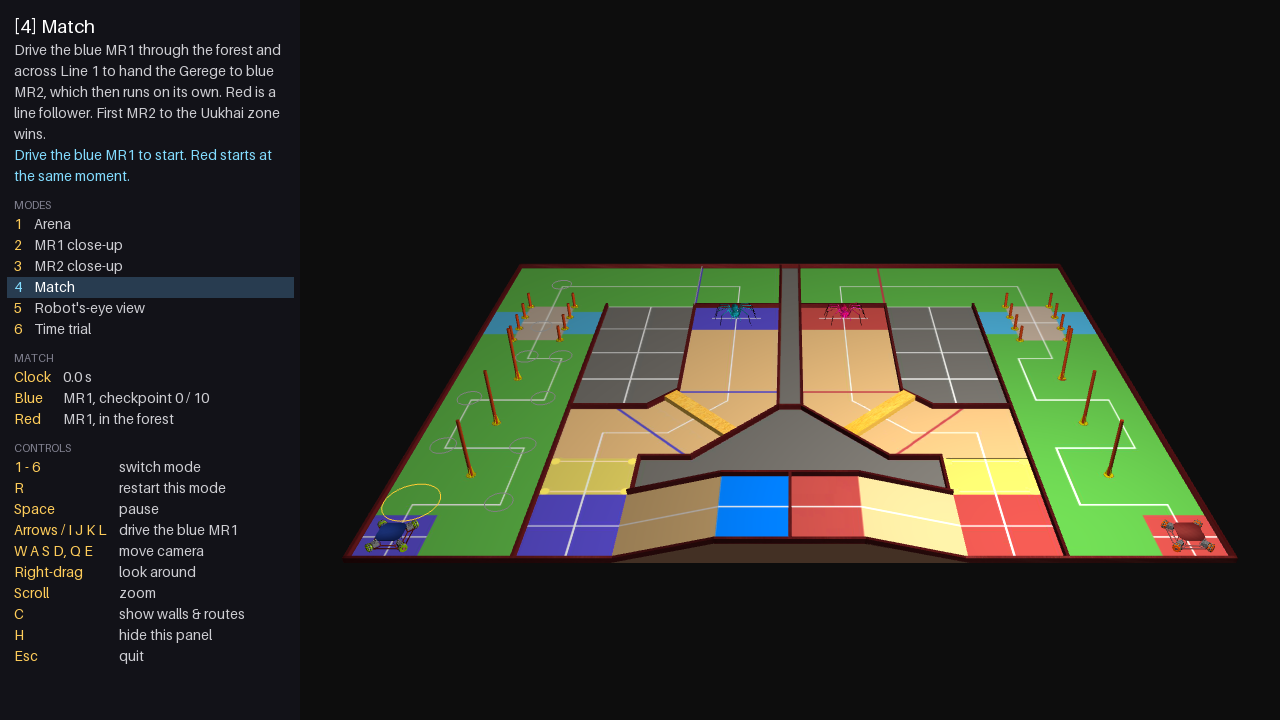
Drive MR1 and hand over to an automatic MR2 in a race against a line-following team, or race a line-follower ghost with split times and a run log.