2026 Thesis
Self-Hosted Agentic LLM Framework
Multi-agentic systems via local LLMs, with typed outputs, deterministic verification, and a self-correction loop, producing auditable results.
Pydantic AIOllamaMulti-AgentText-to-SQLPython
Robotics, simulation, applied data, and hackathon builds. Each one links to a deeper write-up with background, features, and outcomes.
Multi-agentic systems via local LLMs, with typed outputs, deterministic verification, and a self-correction loop, producing auditable results.
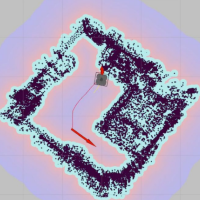
Visual SLAM project to map a room and localize and navigate a mobile robot using one camera, in a scene with people moving. An ICNet segmentation model fine-tuned on our own walking dataset masks out people so their features are not used as landmarks.
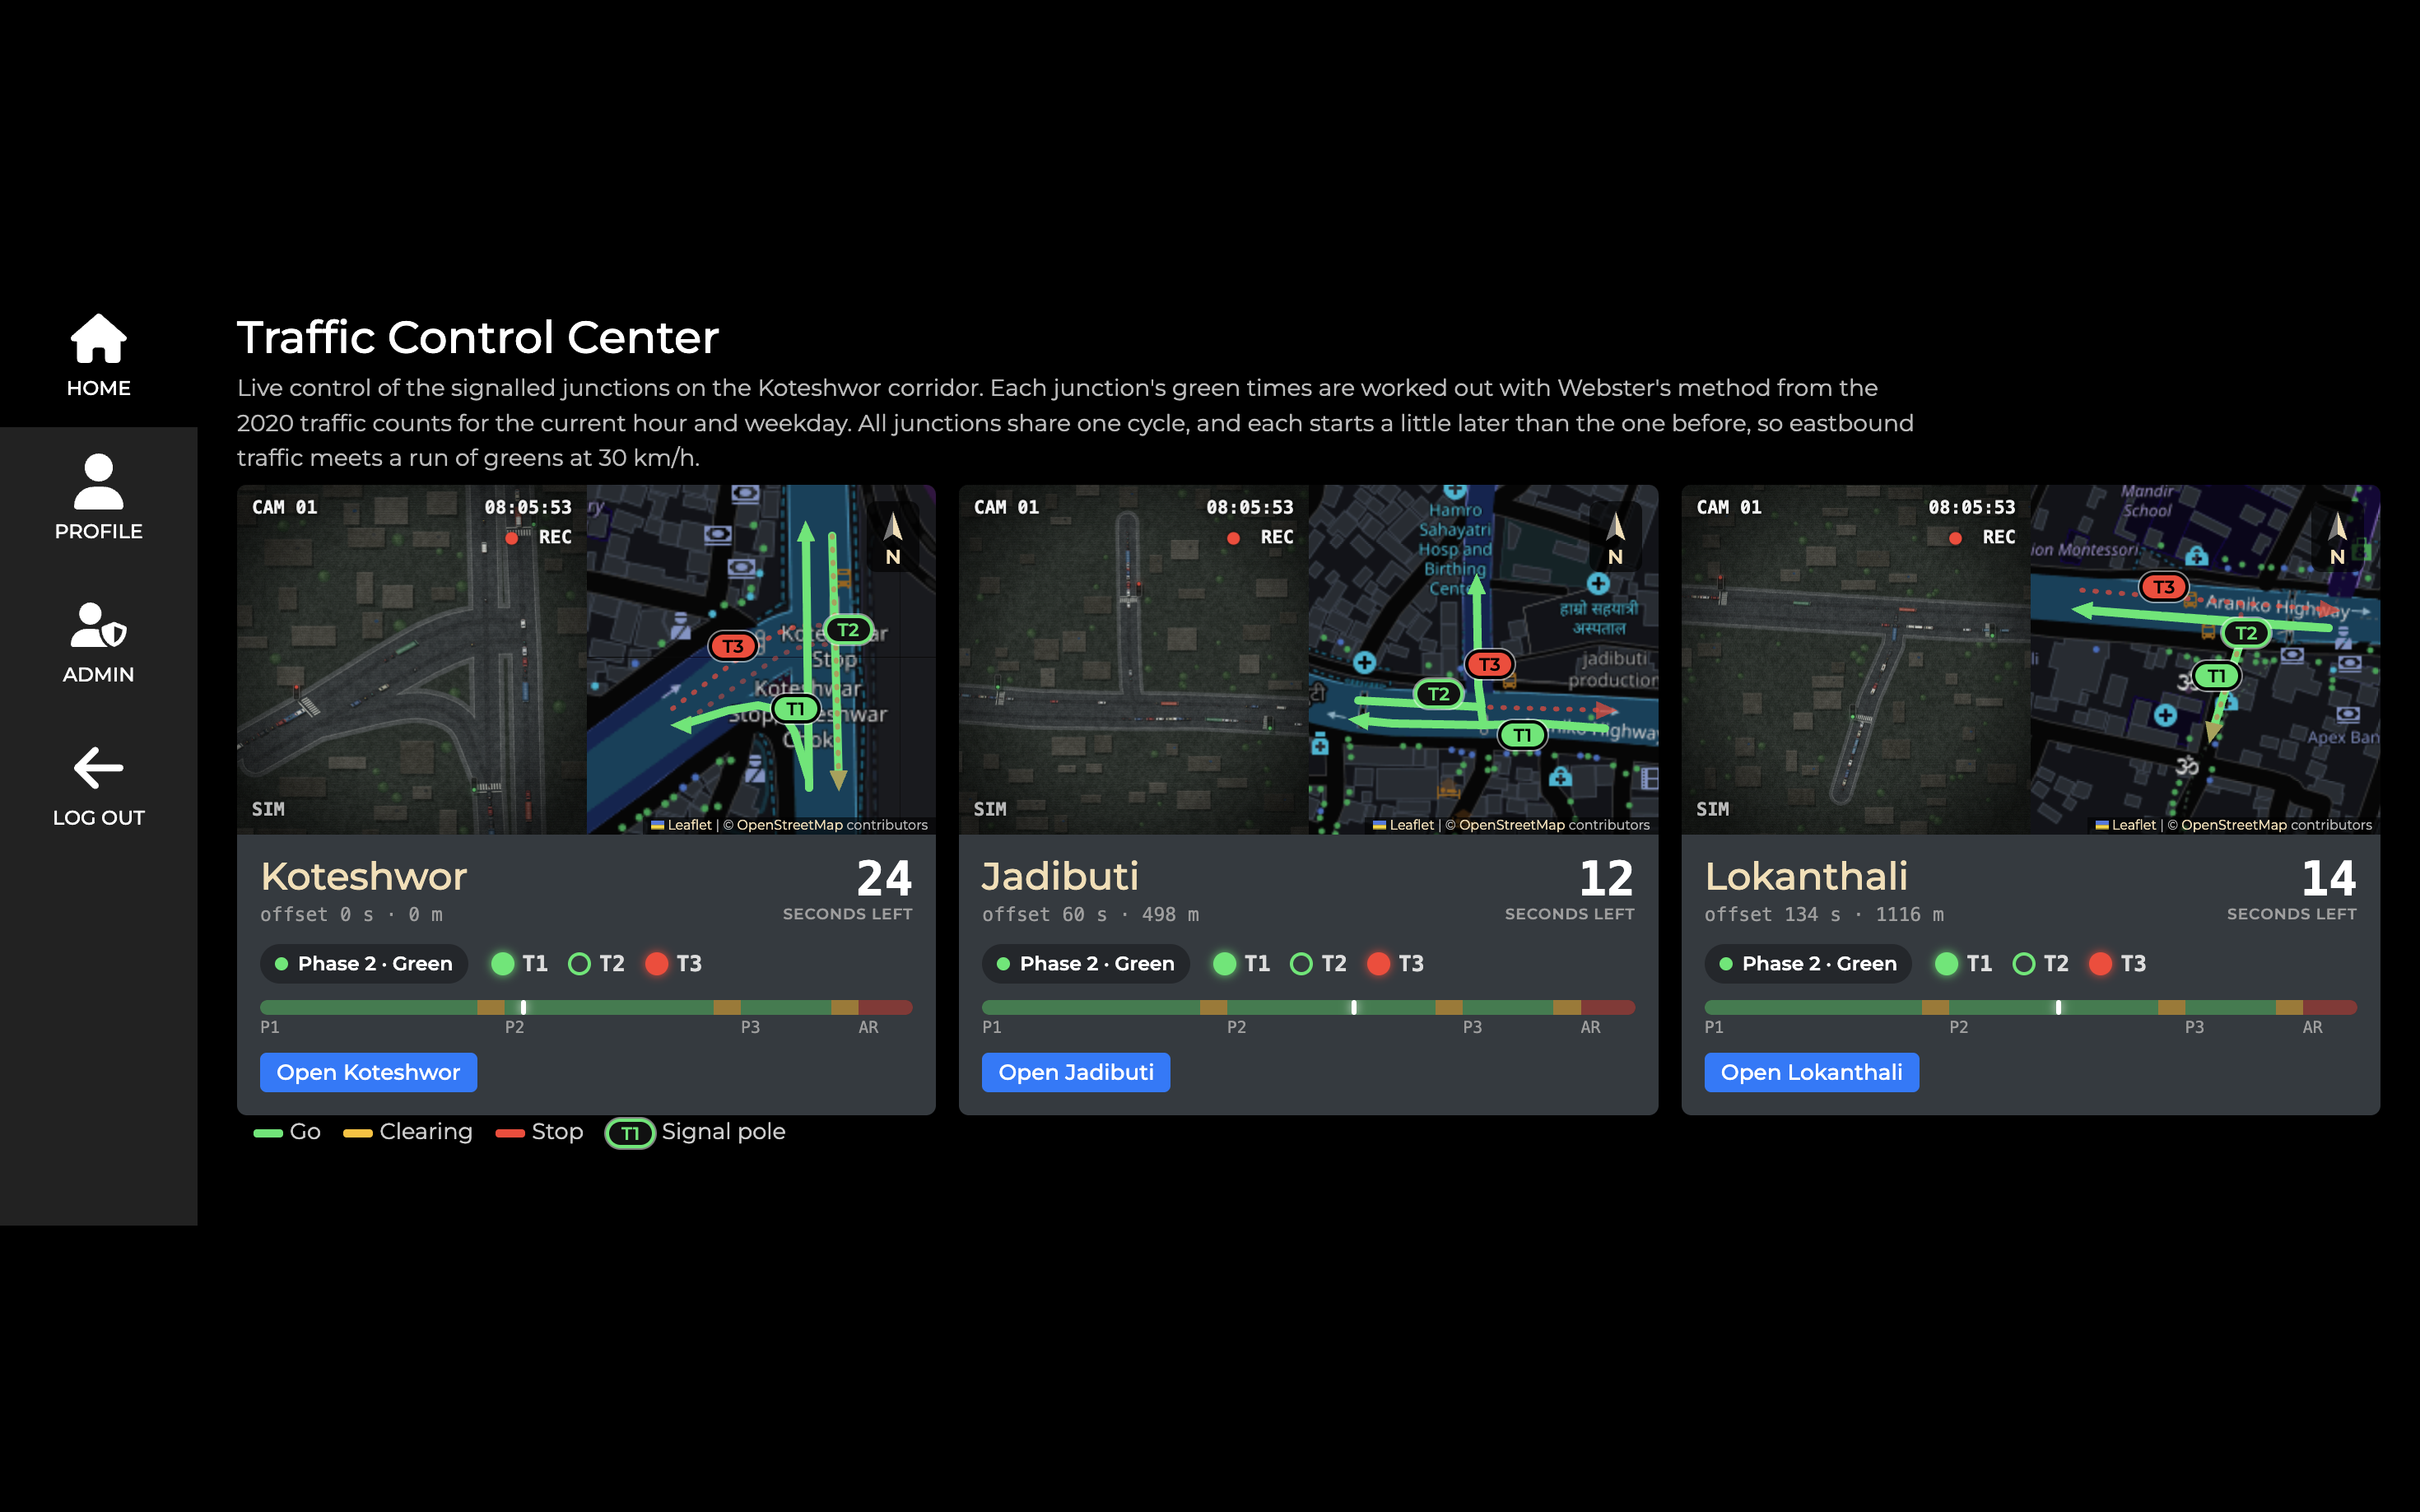
The project addresses traffic jams at Koteshwor, Jadibuti and Lokanthali, where fixed-timing traffic lights cause delays, deadlocks and higher fuel consumption. It began as a semester project and was rebuilt in 2026 as a clock-based Flask app that sets each junction's signal plan from traffic counts and shows it live.
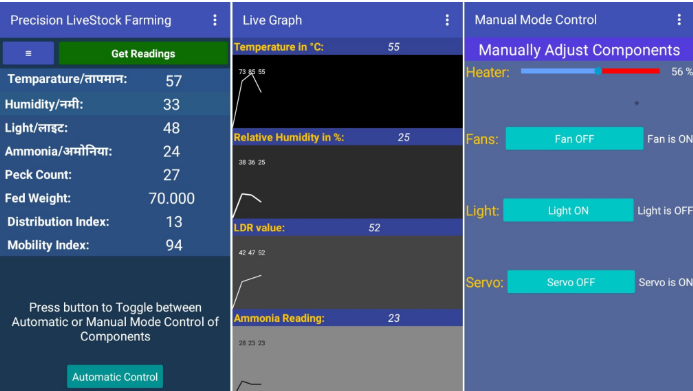
Precision Livestock Farming (PLF) uses advanced technologies to monitor and understand animal behavior and optimize their contribution to the livestock. The prototype monitors broiler chickens using a camera, microphone, and environmental sensors to examine feeding, mobility and distribution, correlated to the well-being and health of the broiler variety.
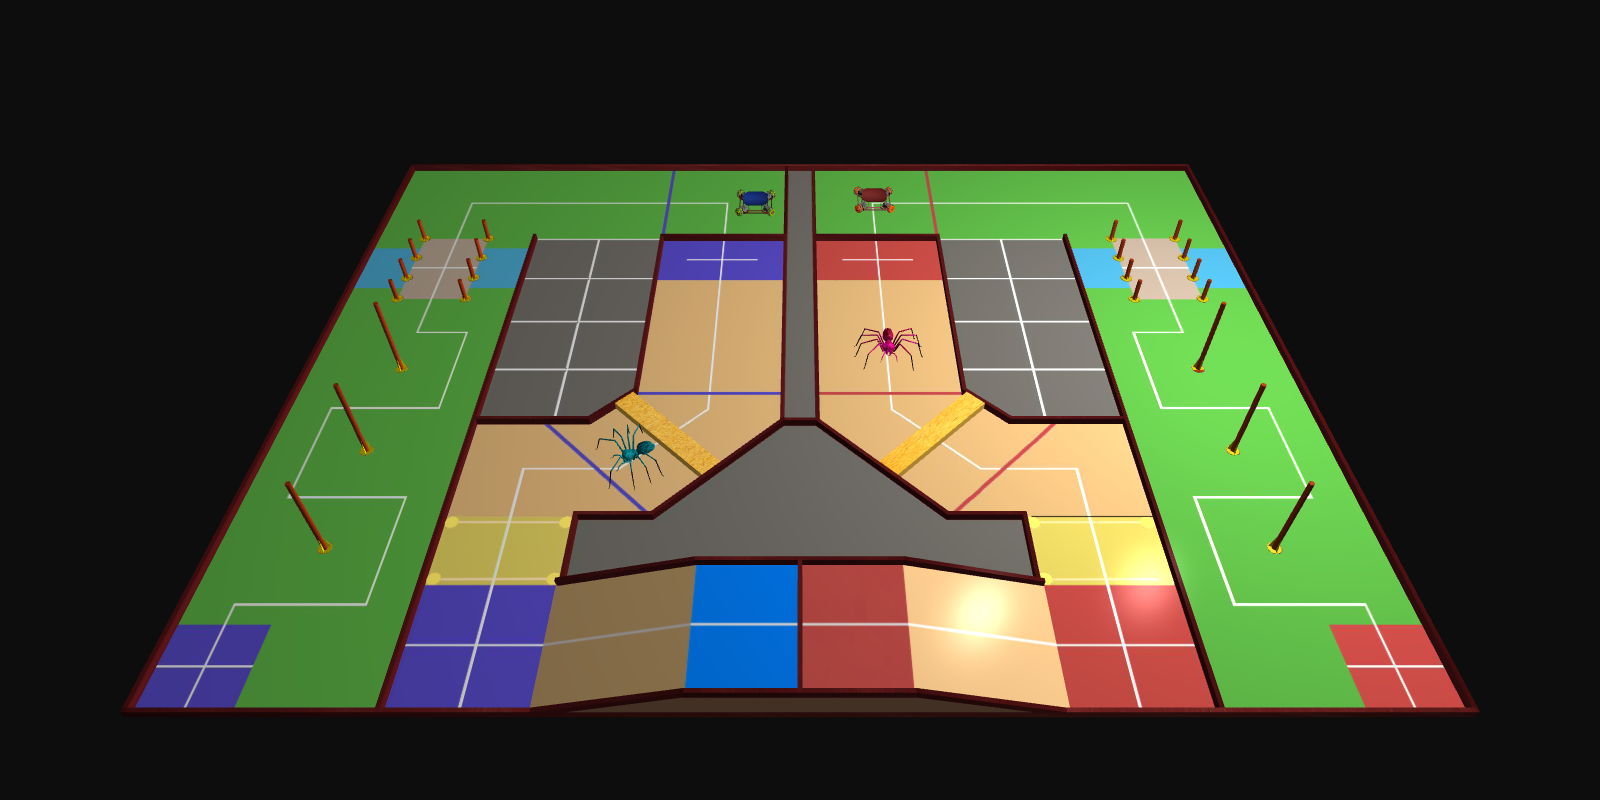
A 3D simulation of the ABU Robocon 2019 "Great Urtuu" contest, rendered with OpenGL. The robots follow the white guidelines from the rulebook, and you can drive MR1 yourself.